S-Curve Acceleration and Jerk Limiting for Precision Motion
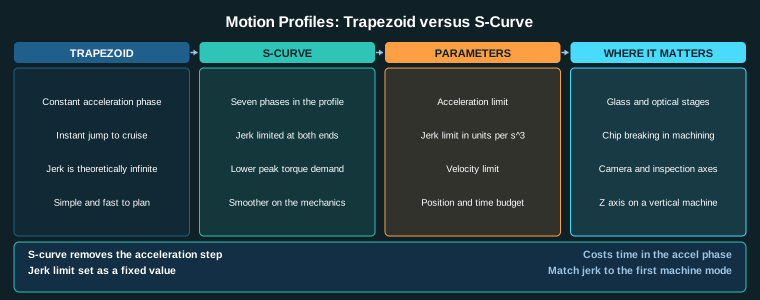
Trapezoidal versus S-curve timing compared, jerk limits, following error, structural excitation and the cycle time cost of smooth acceleration.
Trapezoidal versus S-curve timing compared, jerk limits, following error, structural excitation and the cycle time cost of smooth acceleration.

Key Takeaway: A multi-axis stepper or servo motor controller built on STM32 or ESP32 delivers coordinated XYZ motion with acceleration planning, encoder feedback, and G-code interpretation — enabling custom CNC…